About Me
👋 Welcome to my personal homepage! I am Zijian Zhang, currently an incoming Master's student in Computer Application Technology at the School of Artificial Intelligence, University of Chinese Academy of Sciences. Prior to this, I received my Bachelor's degree in Robotics Engineering from University of Science and Technology Beijing.
🔬 My research interests primarily focus on Robot Learning, World Models, Vision-Language-Action Models, and 3D Perception. I am interested in enabling robots to build compact geometric and semantic representations of the physical world, predict short-horizon dynamics, and perform robust closed-loop manipulation.
🤖 I have worked on 3D Gaussian world models for robotic manipulation, world-action model enhancement, HD map auto-labeling, active LiDAR perception, BEVFusion deployment, and ROBOCON robot control systems. Feel free to contact me!
🔥 News
-
[2026.08] We release GaussianDream++, with paper available.
-
[2026.08] We release GaussianWAM, with paper available.
-
[2026.05] GaussianDream is available on arXiv.
-
[2026.05] Jingdiao Cup Graduation Design Competition, First Prize.
-
[2026.03] Fuse and Refine is submitted to IROS.
-
[2025.08] Software-Defined Parallel LiDARs for Active 3D Perception is completed as a first-author work.
-
[2025.07] Champion, ROBOCON Equestrian Speed Race.
-
[2024.07] Champion, ROBOCON Programming Challenge; Third Place, ROBOCON Granary Challenge.
📝 Publications
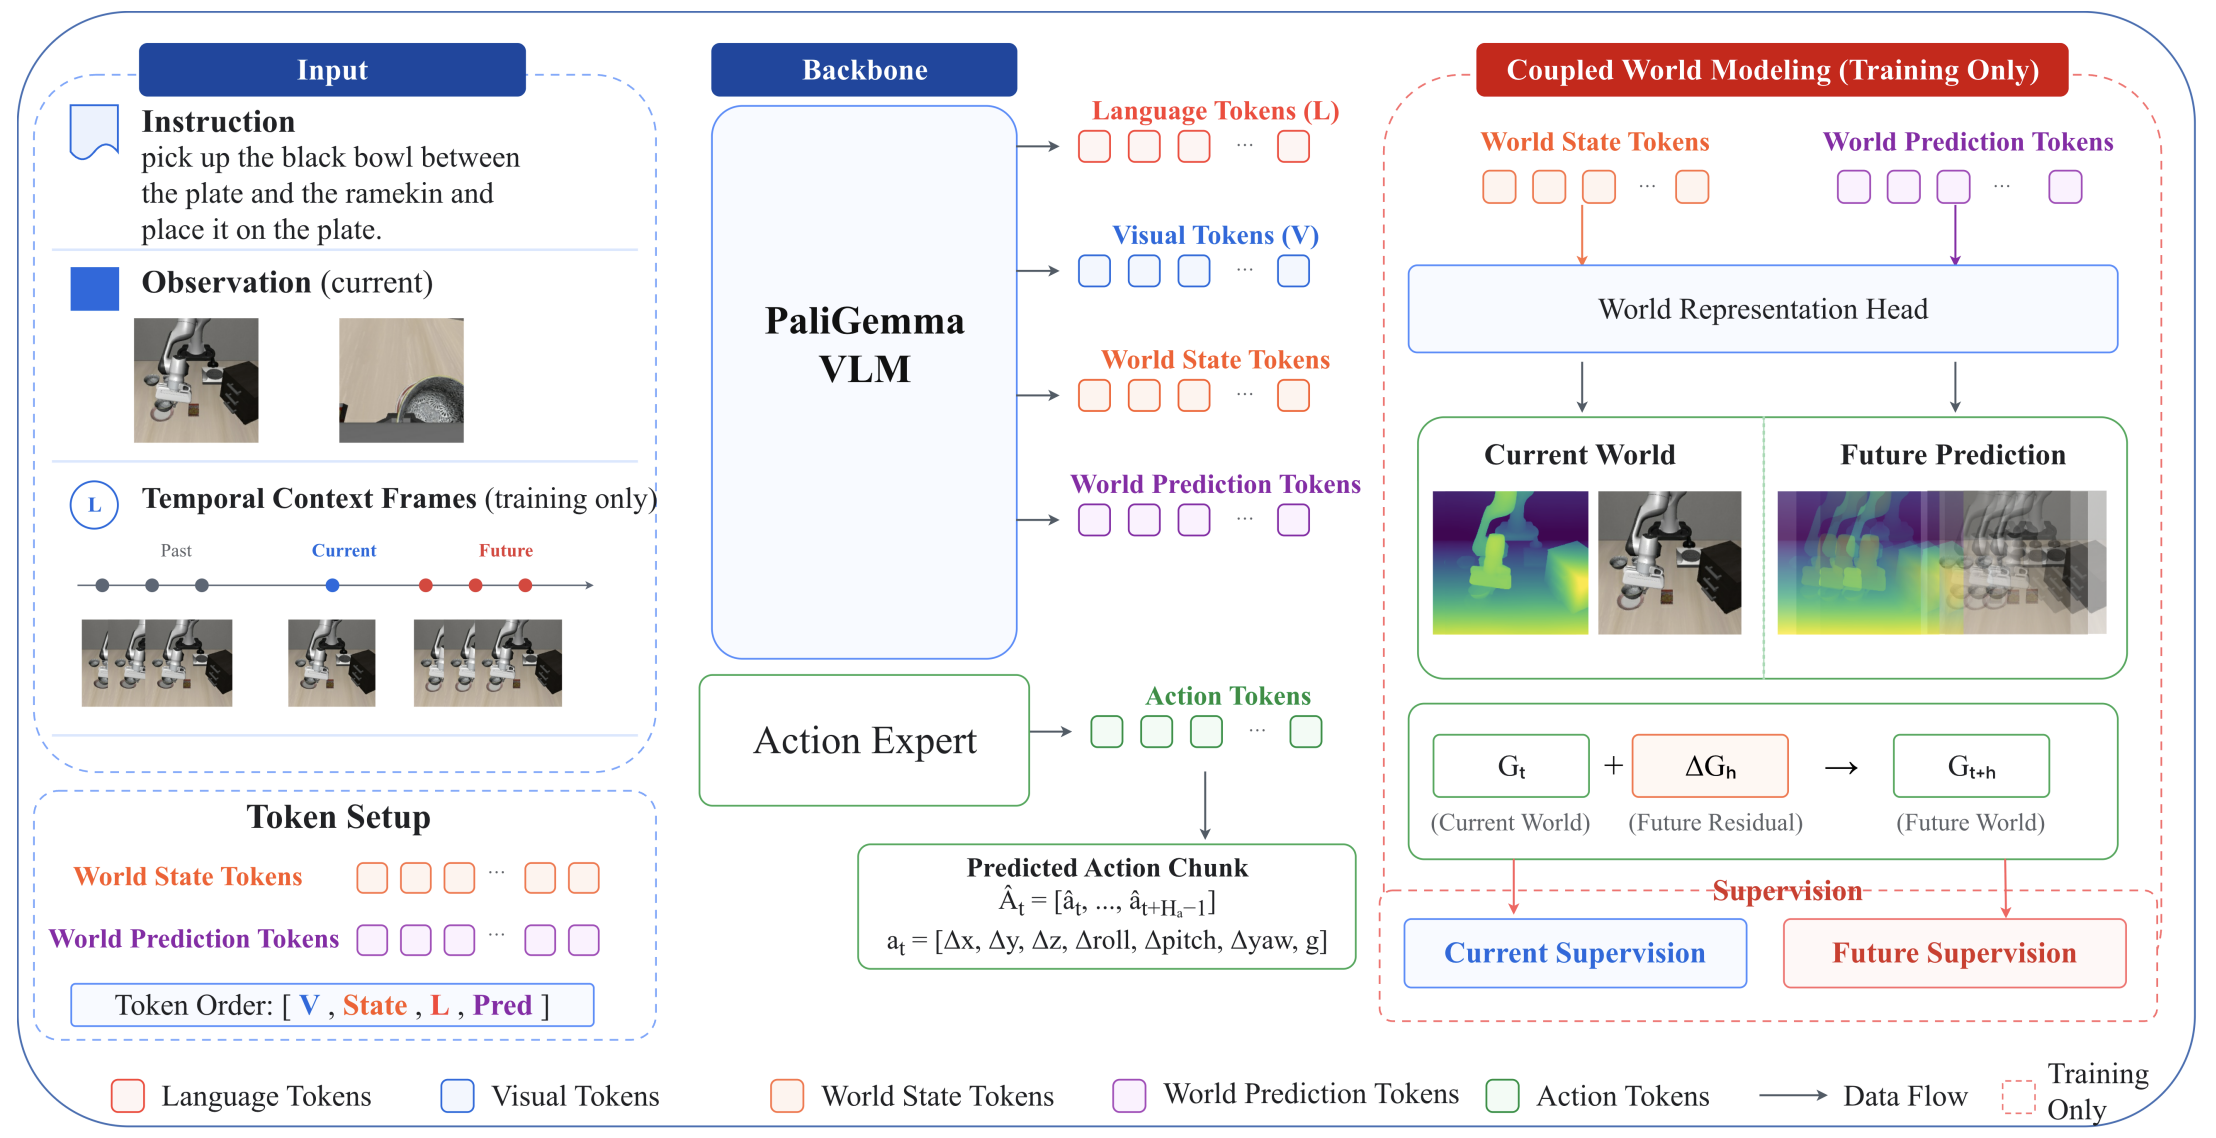
Yuqing Jiang, Zijian Zhang, Weitao Zhou, Jiawei Wang, Junjie He, Lei Yang, Haifang Qing, Si Liu, Ding Zhao, Ping Luo, Haibao Yu.
arXiv, 2026.
Action-compatible 3D world tokens for efficient VLA control.
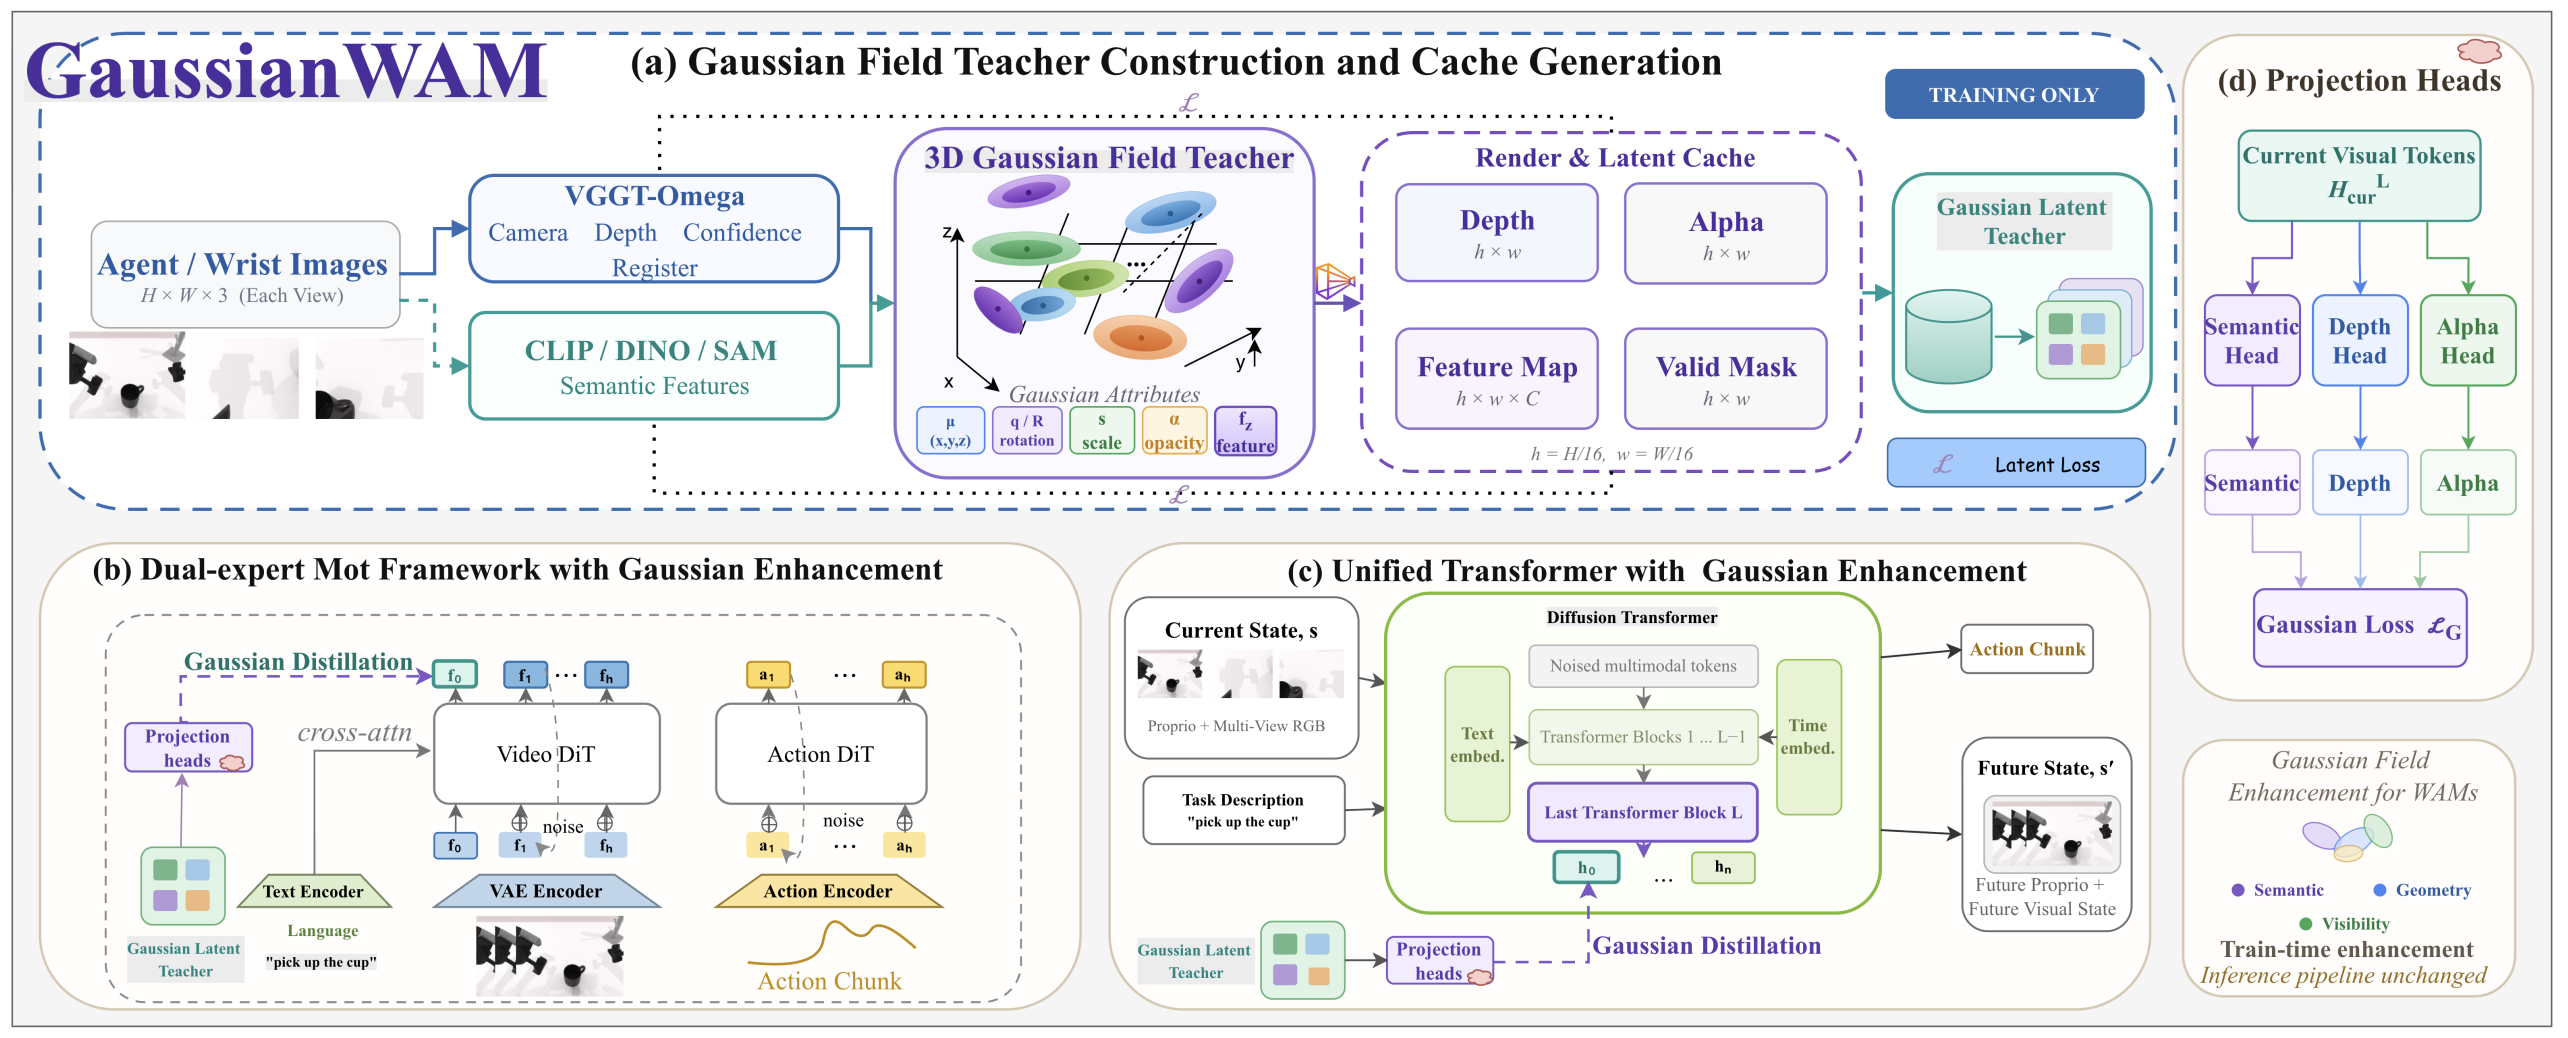
Zijian Zhang, Yuqing Jiang, Weitao Zhou, Minglei Li, Jinhao Zhang, Yao Mu, Xiaofan Li, Hao Zhao, Haibao Yu.
arXiv, 2026.
Injecting 3D geometry and visual semantics into action-relevant WAM representations.
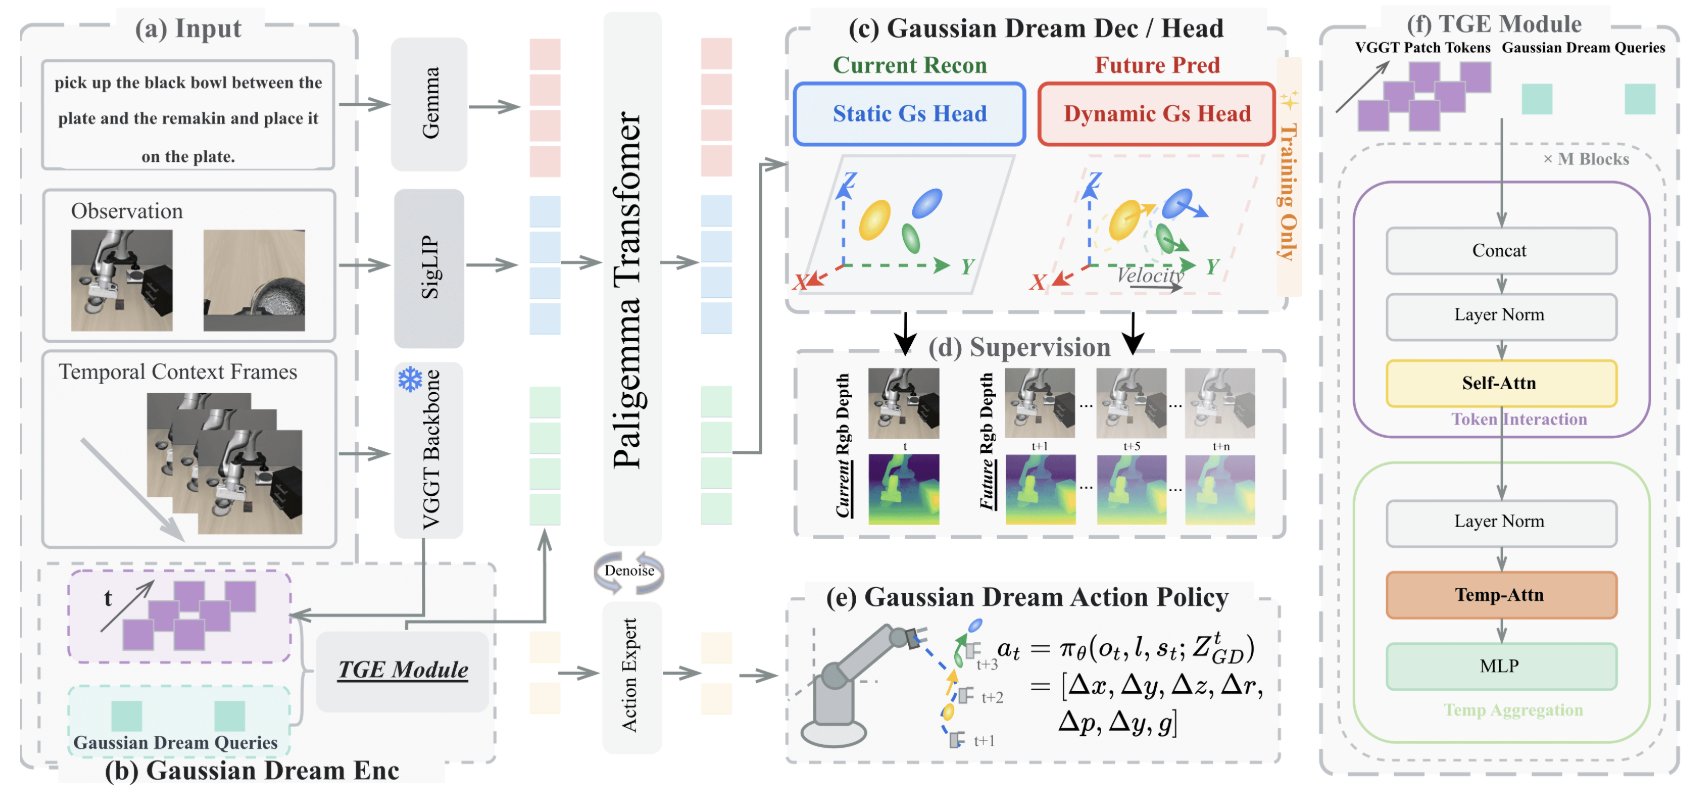
Zijian Zhang, Yuqing Jiang, Qian Cheng, Xiaofan Li, Si Liu, Ding Zhao, Ping Luo, Weitao Zhou, Haibao Yu.
arXiv, 2026.
A 3D Gaussian world model plug-in with current reconstruction and future prediction.
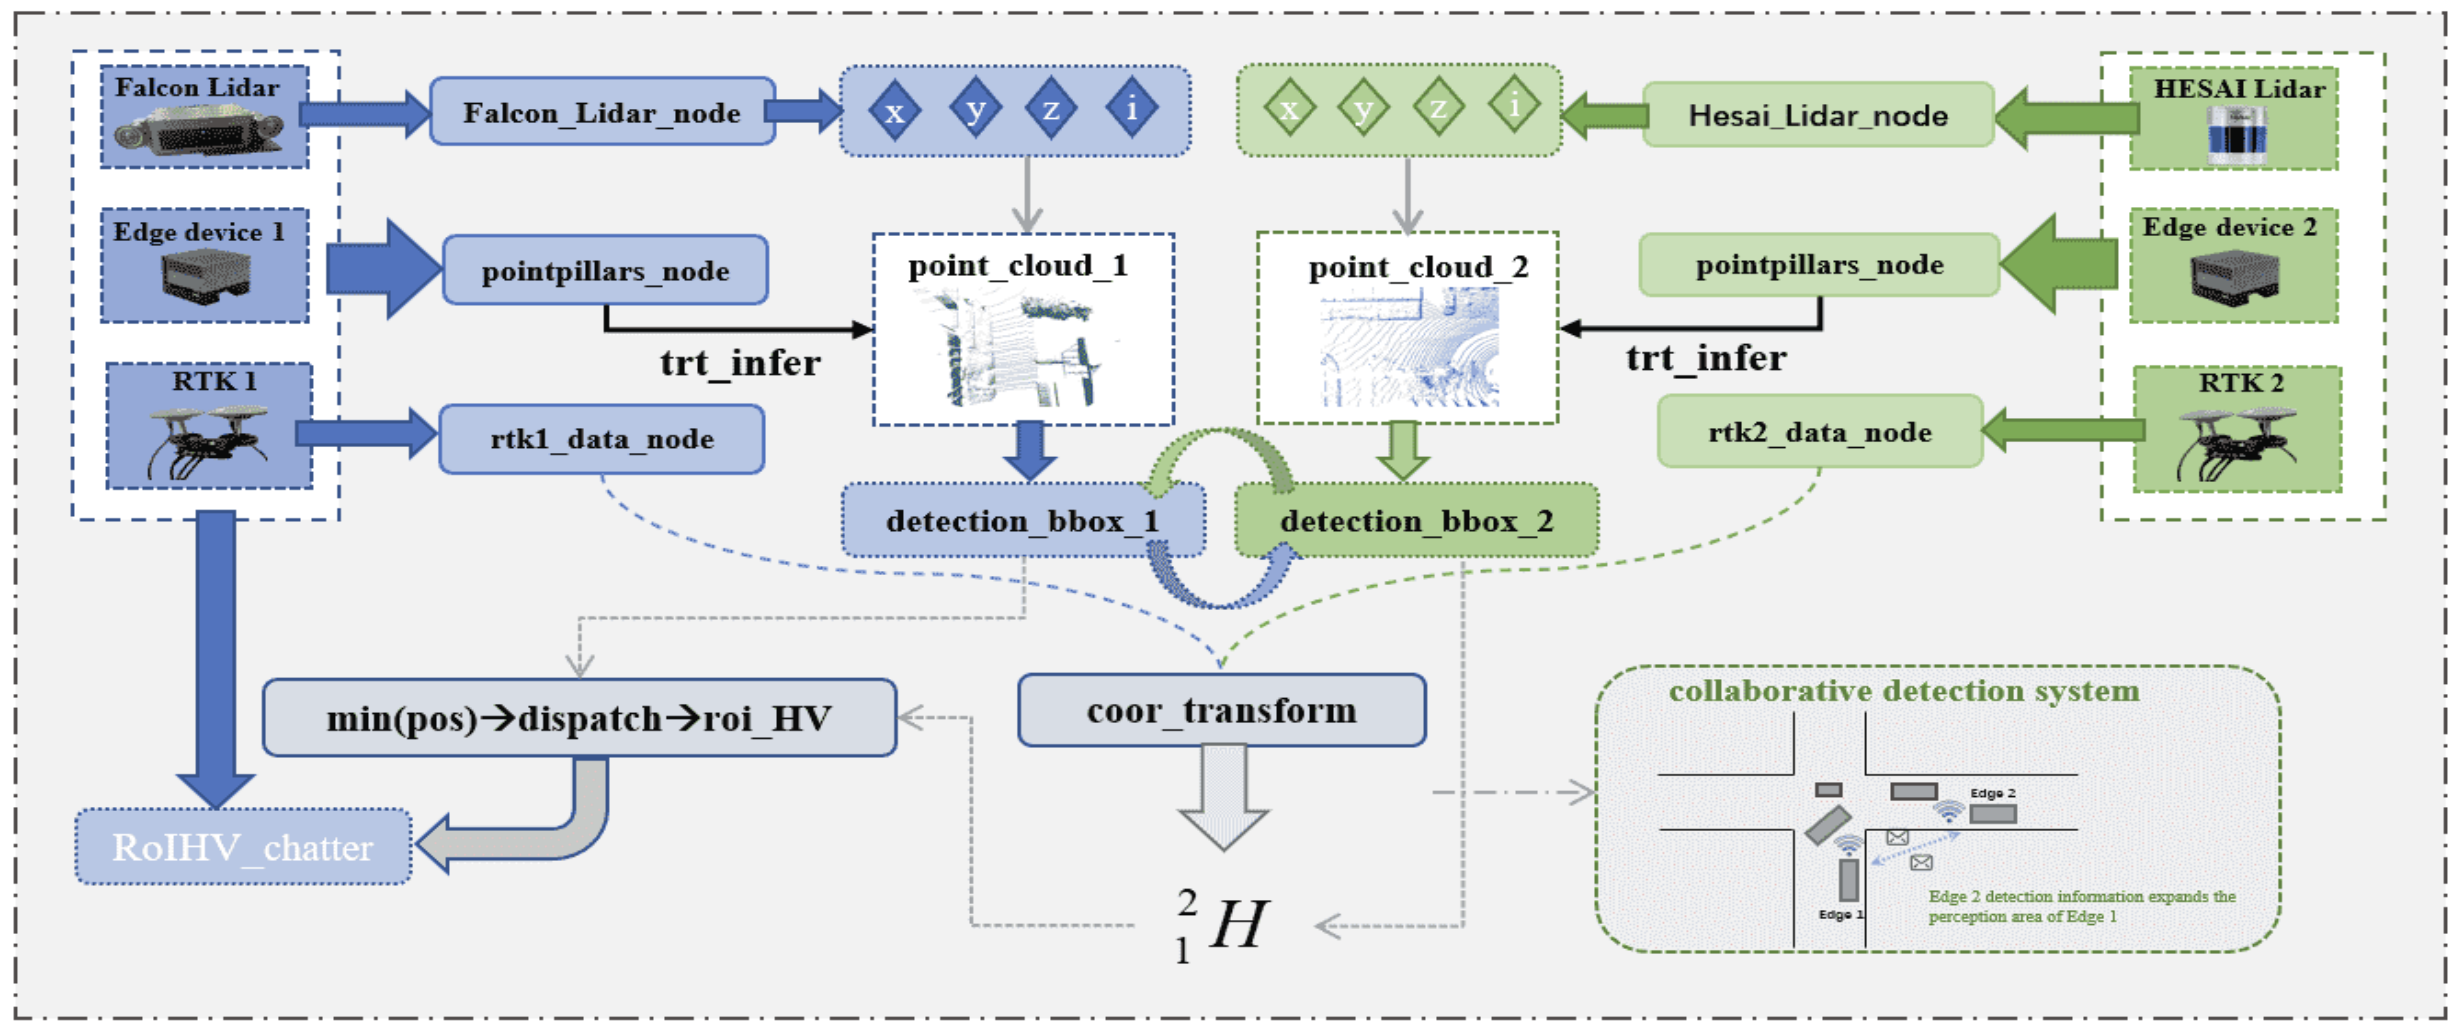
Zijian Zhang, Yuhang Liu, Boyi Sun, Jing Yang, Yutong Wang, Fei-Yue Wang.
IEEE/ASME MESA, 2025.
Collaborative perception and active LiDAR scanning for autonomous-driving scenes.
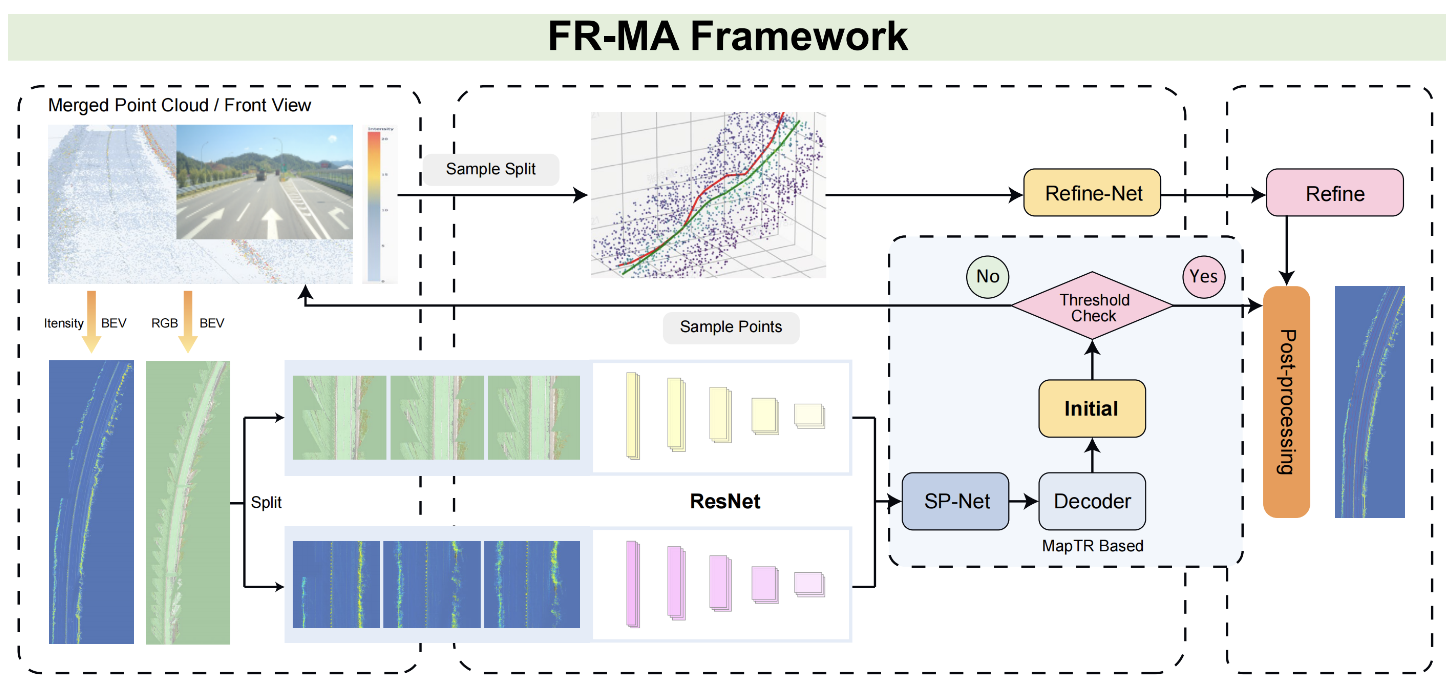
Zijian Zhang, Rui Zhu, Jiansong Chen, Wenbo Li, Jun Xiao, Dongbo Yu* (512243, 511837, 511369, 506108, 476103, 474401).
Submitted to IROS, 2026.
Robust and accurate HD map auto-labeling for large-scale autonomous-driving scenes.
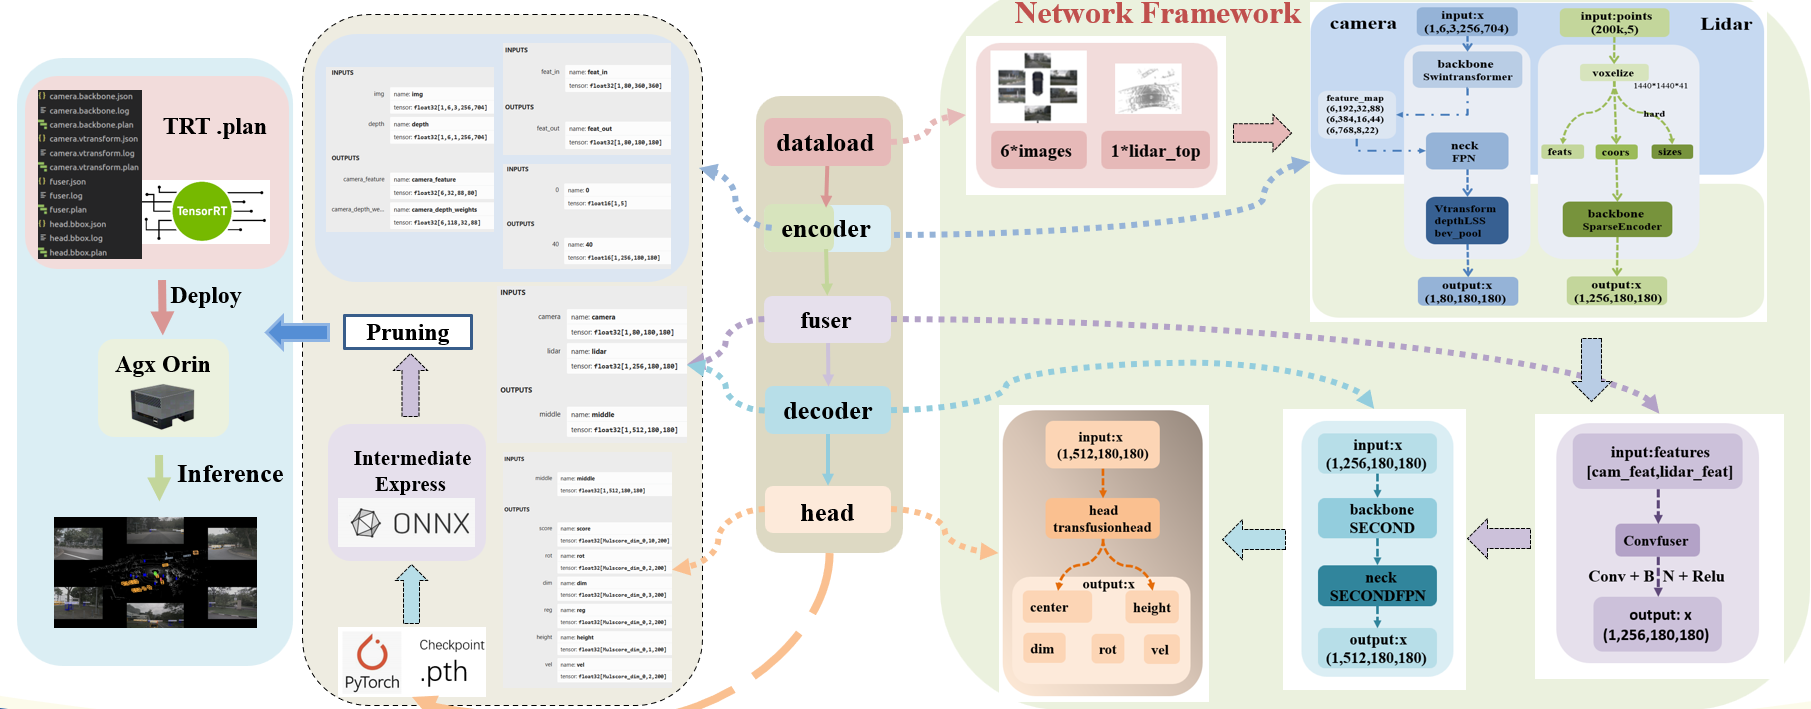
Zijian Zhang.
Engineering Project, 2025.
Multimodal 3D detection, pruning, TensorRT acceleration, and NVIDIA Orin deployment.
Zijian Zhang.
MEI Competitive Robotics Lab, 2023.08 -- 2024.08.
Electrical control system development, communication networks, cascaded PID control, chassis control, and competition robot development.